

|
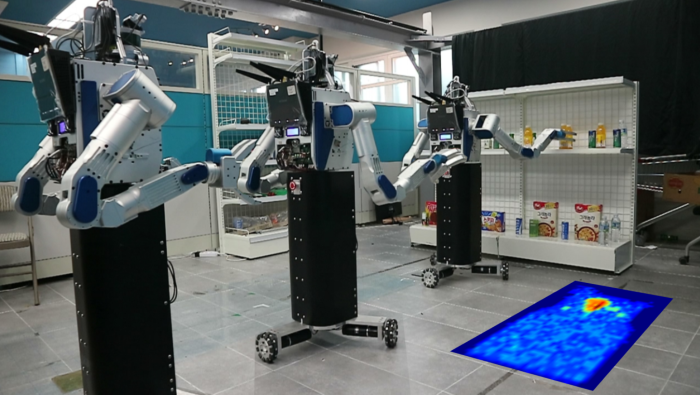
Hubo mobile robot in a mock-up convenient store, approaching to grap a bottle.
It is expected that robots with some sort of intelligence will be a part of our lives in future. Many challenges are ahead of us to realize robots to be a part of our lives. In this course, we will consider issues of motion planning of real and virtual robots for various applications. We will focus more on virtual robots and their applications in games, movies, virtual prototyping, crowd simulations. We will go over basic materials related to motion planning and their applications.
What you will get at the end of the course:
What you will do:
Lecture schedule (subject to change)
| # of lecture, date | Topics and lecture slides | Related material(s) / Note(s) |
| Aug - 31 | Lecture1: Introduction | Intro. pdf |
| Sep - 2 | Lecture2: The Robot Planning | |
| Sep - 7 | Lecture3: Neural Planning | |
| Sep - 9 | Lecture4: Planning in the Wild | |
| Sep - 14 | Lecture5: Generative Trajectory Topography | |
| Sep - 16 | ||
| Sep - 21 | Lecture7: Learning based approaches | |
| Sep - 23 | ||
| Sep - 28 | T8 | Student Lecture Presentation |
| Sep - 30 | T3, T7 | Student Lecture Presentation |
| Oct - 5 | ||
| Oct - 7 | T5, T4 | Student Lecture Presentation |
| Oct - 12 | T1, T2 | Student Lecture Presentation |
| Oct - 14 | T6, T9 | Student Lecture Presentation |
| Oct - 19 | Mid-term Exam (Official Mid-term Exam Period) | |
| Oct - 21 | Mid-term Exam (Official Mid-term Exam Period) | |
| Oct - 26 | T8, T6 | Student Paper Presentation |
| Oct - 28 | T1, T9 | Student Paper Presentation |
| Nov - 2 | T4, T2, T5 | Student Paper Presentation |
| Nov - 4 | T3, T7 | Student Paper Presentation |
| Nov - 9 | T7 | Mid-term Project Presentation |
| Nov - 11 | T4, T9 | Mid-term Project Presentation |
| Nov - 16 | T3, T2 | Mid-term Project Presentation |
| Nov - 18 | T1, T5 | Mid-term Project Presentation |
| Nov - 23 | T8, T6 | Mid-term Project Presentation |
| Nov - 25 | T6 | Final Project Presentation |
| Nov - 30 | T3, T4 | Final Project Presentation |
| Dec - 2 | T7, T2 | Final Project Presentation |
| Dec - 7 | T5, T9 | Final Project Presentation |
| Dec - 9 | T1, T8 | Final Project Presentation |
| Dec - 14 | (Official Final Exam Period) | |
| Dec - 16 | (Official Final Exam Period) |
Presentation rounds: Student Lecture Presentation (Sep 28 ~ Oct 14) · Student Paper Presentation (Oct 26 ~ Nov 4) · Mid-term Project Presentation (Nov 9 ~ Nov 23) · Final Project Presentation (Nov 25 ~ Dec 9)
- Team 1 (T1): 이승민 · 김채원 · 박준수
- Team 2 (T2): 박봉경 · 김민균 · 좌은빈 · 류경찬
- Team 3 (T3): Aleksandra Filippa Ciuk Olsson · Premysl Cerny · Guillame Py
- Team 4 (T4): 최본재 · 조승호 · 최민준
- Team 5 (T5): 강우송 · 김건우 · 전민규
- Team 6 (T6): 이동우 · 조현서 · 백두진
- Team 7 (T7): 나영주 · 남지훈 · 양지윤
- Team 8 (T8): 김태연 · 박재형 · 정진우
- Team 9 (T9): 이상민 · 박찬영 · 김기현
For your presentations, please use the this powerpoint template (not mandatory); paper presentation guideline is available.
Paper presentation: cover one recent paper published in 2022 or later at a top-tier venue (Core robotics: ICRA, IROS, RSS · Robot learning: CoRL · AI & ML: NeurIPS, ICML, ICLR · Planning & autonomous systems: AAAI, WAFR). Talk about high-level ideas and results rather than low-level details: motivation, broad background on the related work, the main idea and results, and the strengths and weaknesses of the method. Each talk is 15 minutes including a short quiz (two simple questions, graded on a 0~10 scale and reported to the TA).
Student lecture presentation: cover a sub-topic of motion planning (or Physical AI), or a few somewhat older papers published in 2020 or later – for example the categories discussed in the related work section of your paper presentation. You may reuse tutorial or course slides from conferences; please give proper credit. See the student lecture topic list.
After each talk, please fill in the student talk evaluation form. Evaluate each talk objectively on its own; do not rank the talks against each other.
Previous lecture videos:
Lecture youtube playlist
Additional reference materials and links
Possible project topics from Prof. Latombe's class
Previous course homepage: Fall 25 Fall 23 Fall 20 Fall 19 Spring 17 Fall 15 Fall 13 Fall 11 Fall 09
Links to websites of some well-known researchers in motion planning
Paper search:
Acknowledgements:
The course materials are based on those of Prof. Dinesh Manocha (UNC-Chapel Hill) and Prof. David Hsu (NUS).
Thank you so much!
Copyright 2011. Personal use of this material is permitted. However, permission to reprint/republish this material for advertising or promotional purposes or for creating new collective works for resale or redistribution to servers or lists, or to reuse any copyrighted component of this work in other works must be obtained from the author.
This material is presented to ensure timely dissemination of scholarly and technical work. Copyright and all rights therein are retained by authors or by other copyright holders. All persons copying this information are expected to adhere to the terms and constraints invoked by each author's copyright. In most cases, these works may not be reposted without the explicit permission of the copyright holder.